Tarun Malarvasan

Mechanical engineering, Penn State

Robotics and humanoids: actuators, mechanisms, perception

Researching at the Locomotion in Biology and Robotics Lab

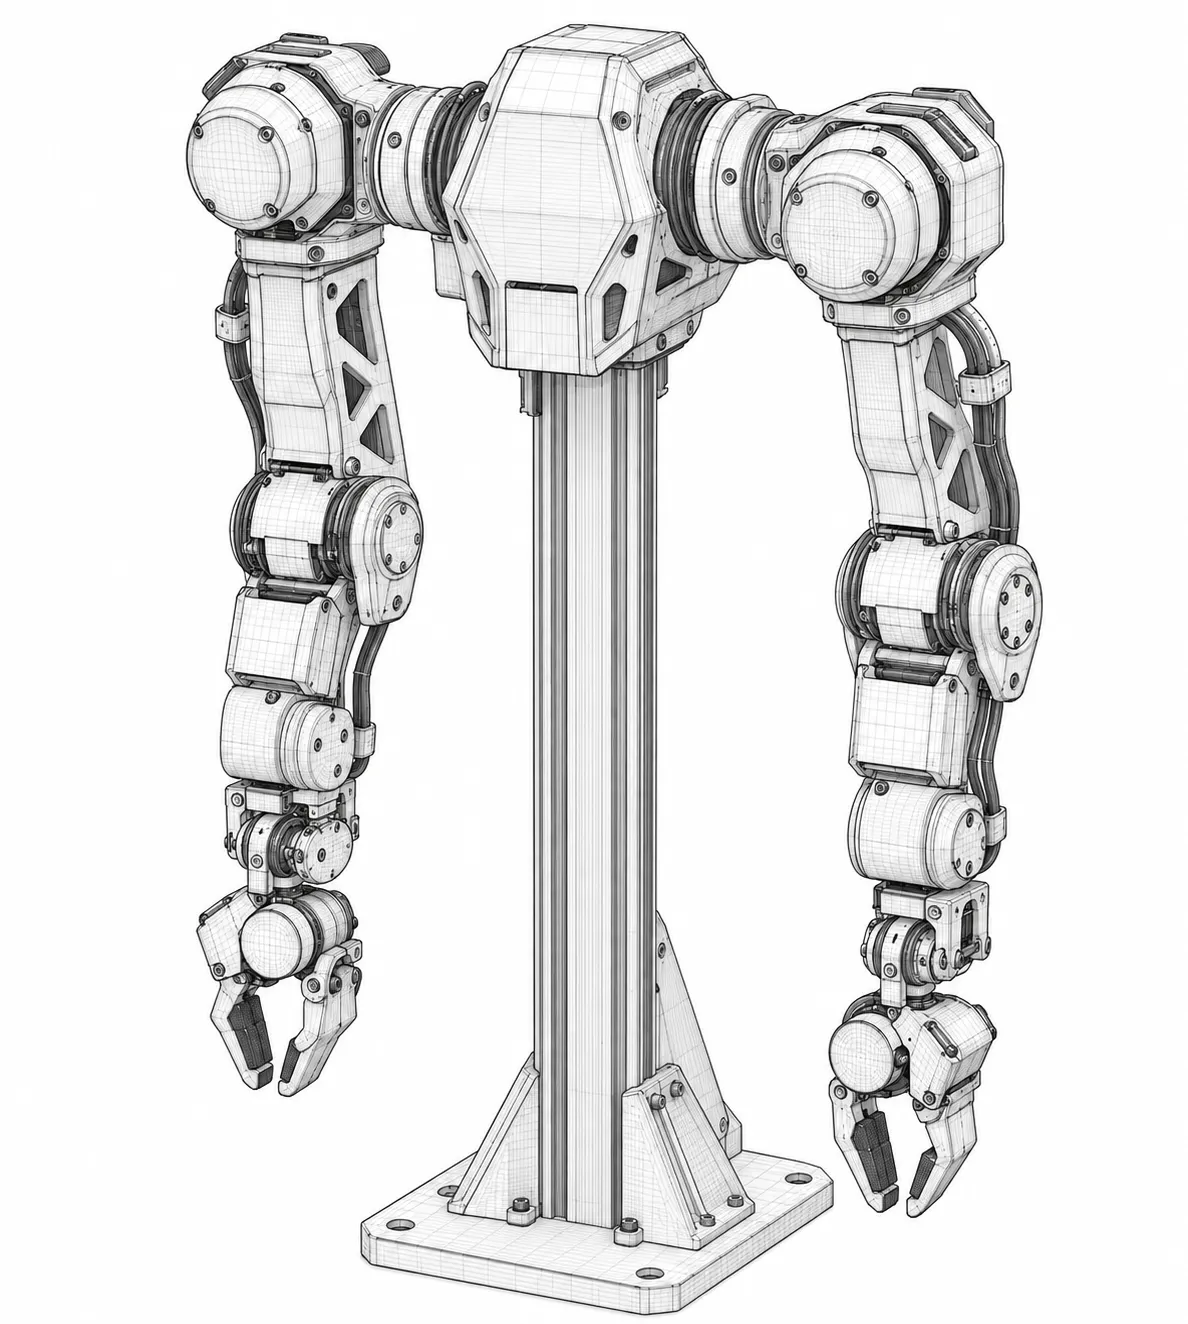
Line drawing of the bimanual arm seen from the front, both six-axis arms hanging from a hexagonal torso hub on a square-section post and base plate, each arm running shoulder actuator, webbed upper link, elbow, forearm and a two-finger servo gripper

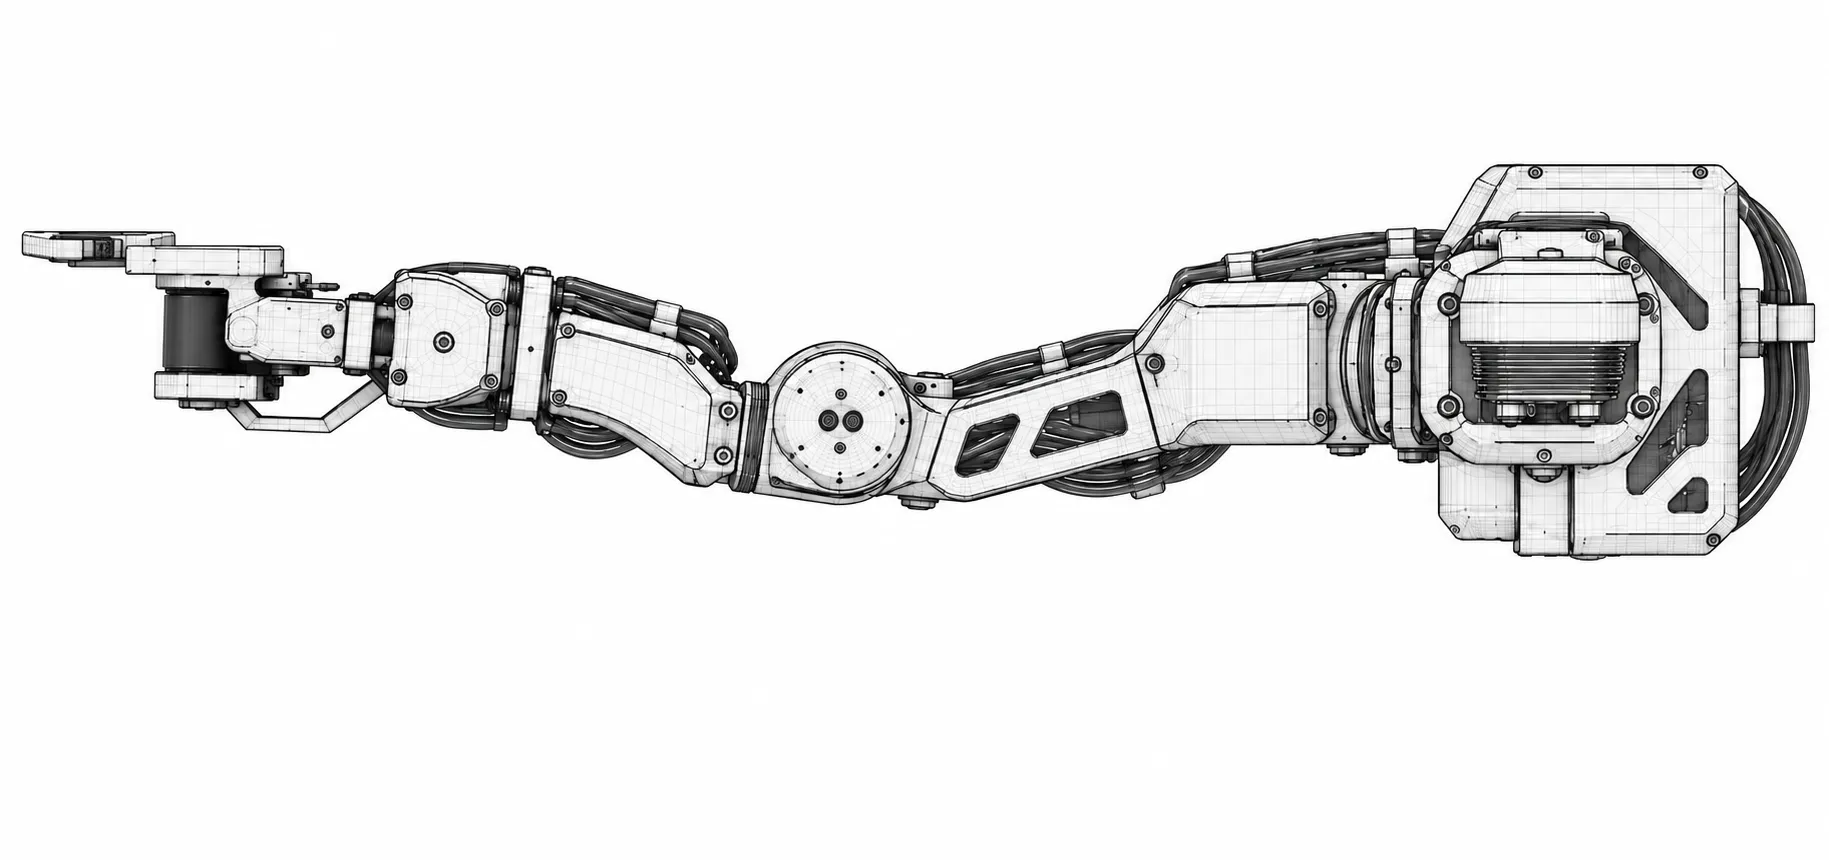
A torso-mounted bimanual arm for imitation-learning data collection, built from quasi-direct-drive BLDC actuators, a brushless motor behind a single low-ratio planetary stage rather than a high-ratio gearbox. That is what keeps every joint backdrivable enough to be moved by hand through a demonstration, and every actuator cheap enough to repeat across both arms.
Learn moreAll projects

May 2026 – PresentSan Francisco, CACurrent

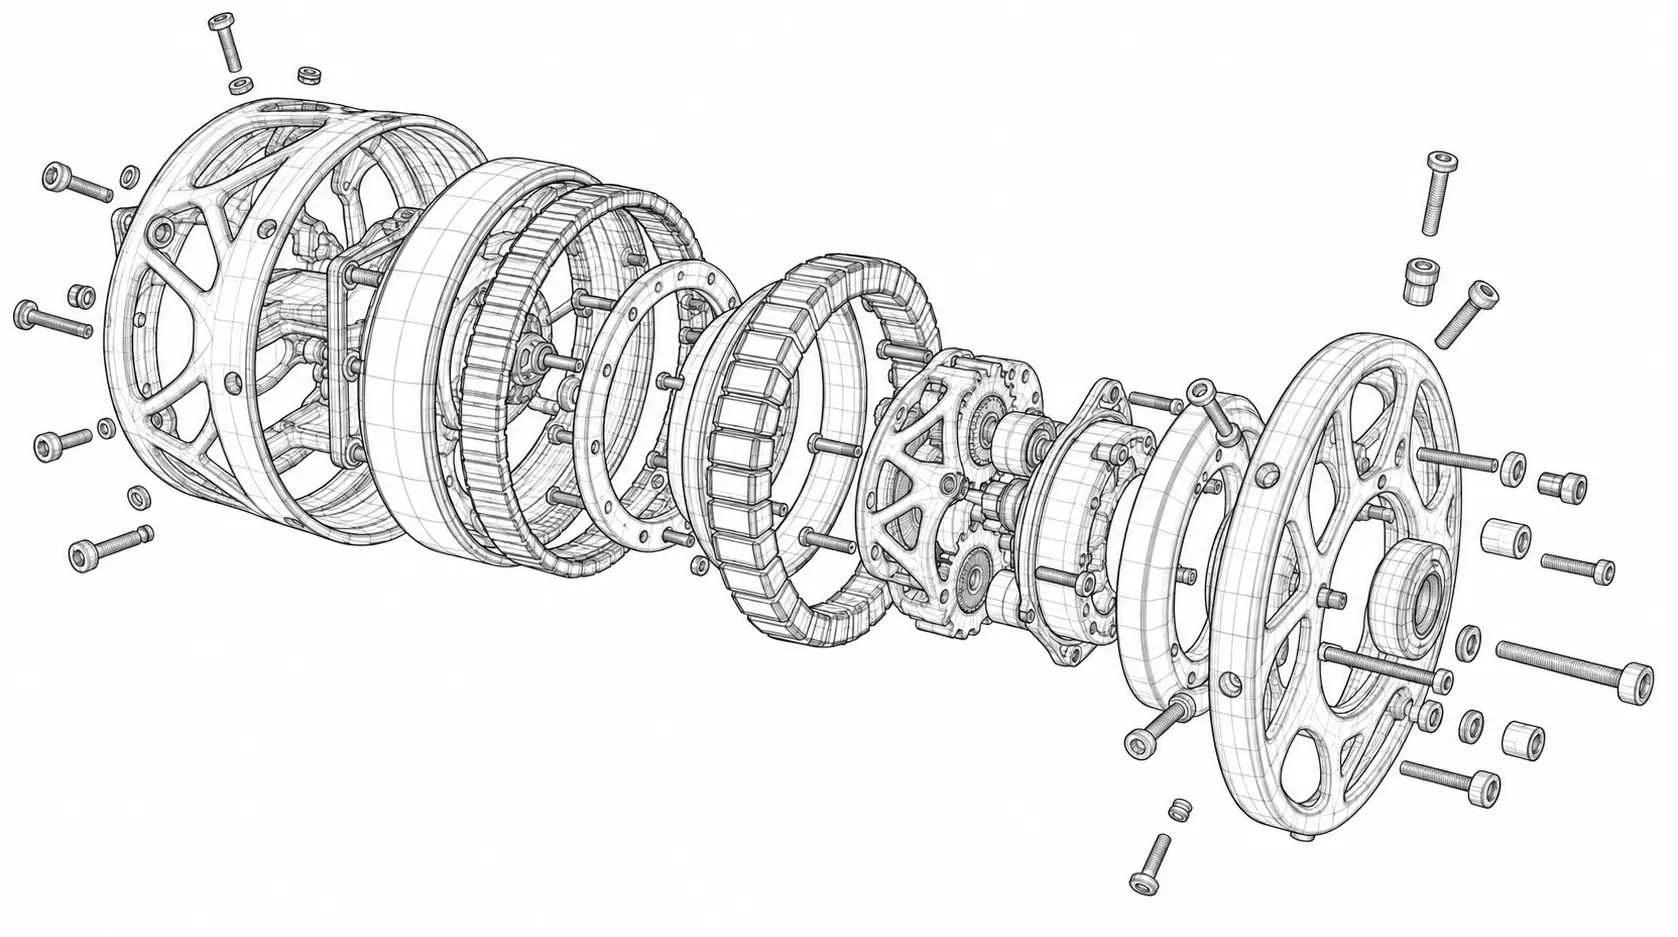
Exploded isometric line drawing of the actuator, showing the ribbed printed housing, stator stack, planet carrier and spoked output flange laid out along the assembly axis with their fasteners

Building a planetary actuator for humanoid joints, designed from the start to be metal 3D printed rather than machined.

All experience