Experience
Founder
Stealth Startup
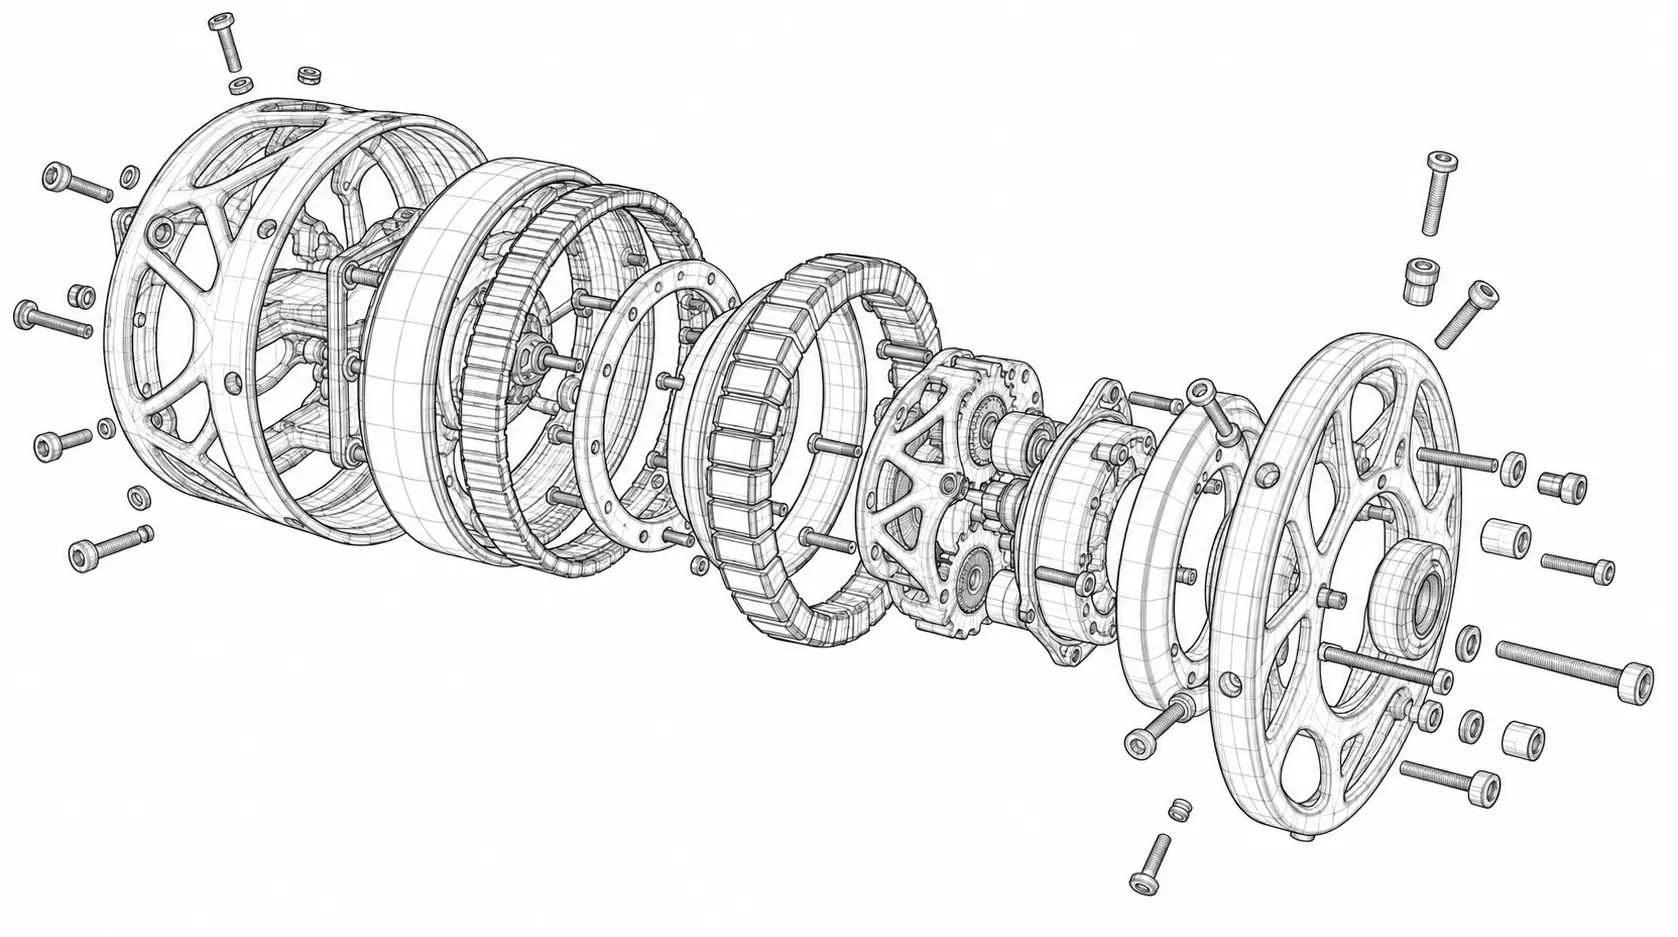
Building a planetary actuator for humanoid joints, designed from the start to be metal 3D printed rather than machined.
Undergraduate student researcher
Penn State Locomotion in Biology and Robotics Lab
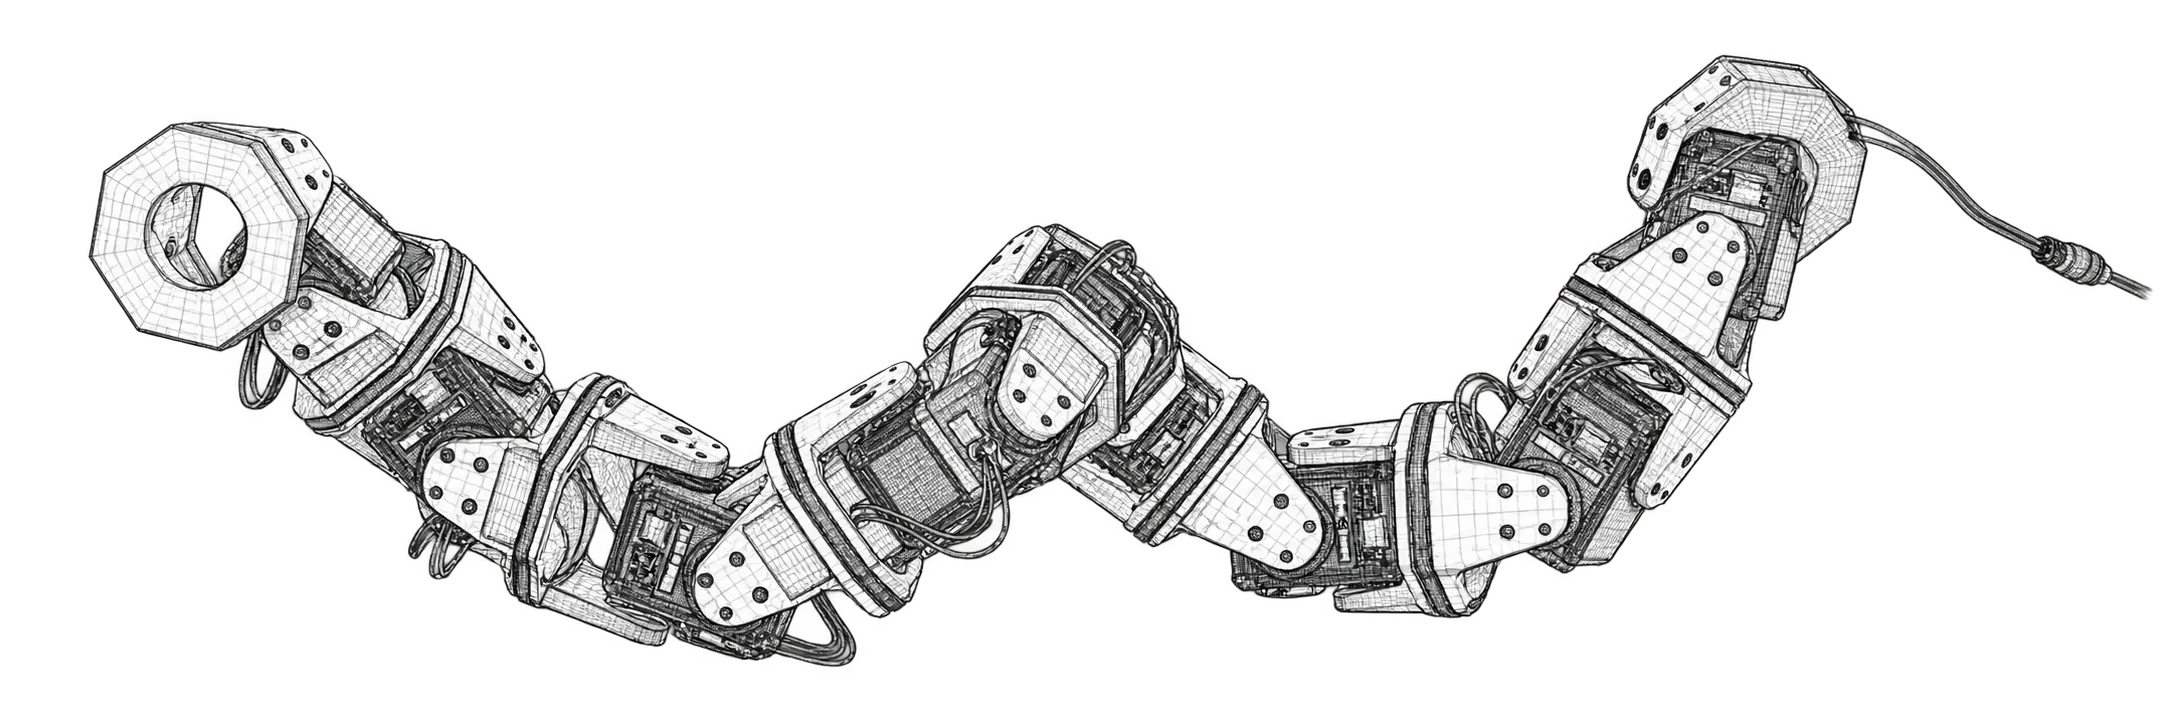
Developing computer vision algorithms to track performance of a centipede robot's sidewind and roll through terrain.
Student researcher
Harvard Undergraduate OpenBio Laboratory
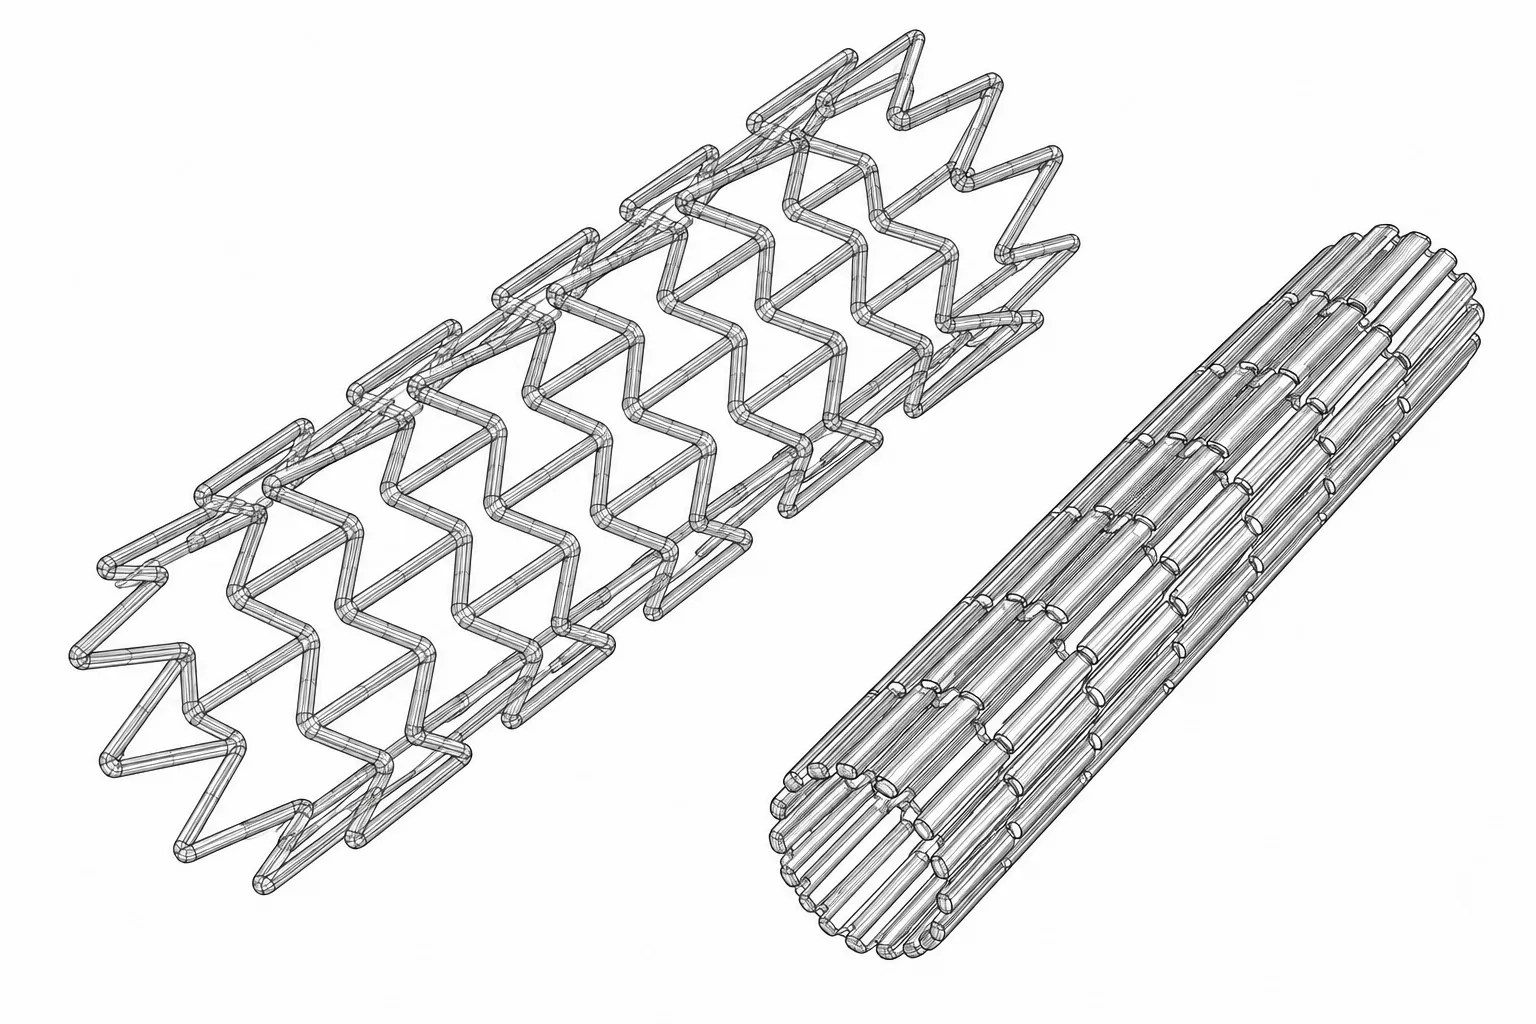
A fellowship that funded PN-003 as personal research rather than a lab assignment: bi-stable auxetic stent structures, optimised through computational modelling, to mitigate restenosis.
Student researcher
Carnegie Mellon Biorobotics Laboratory
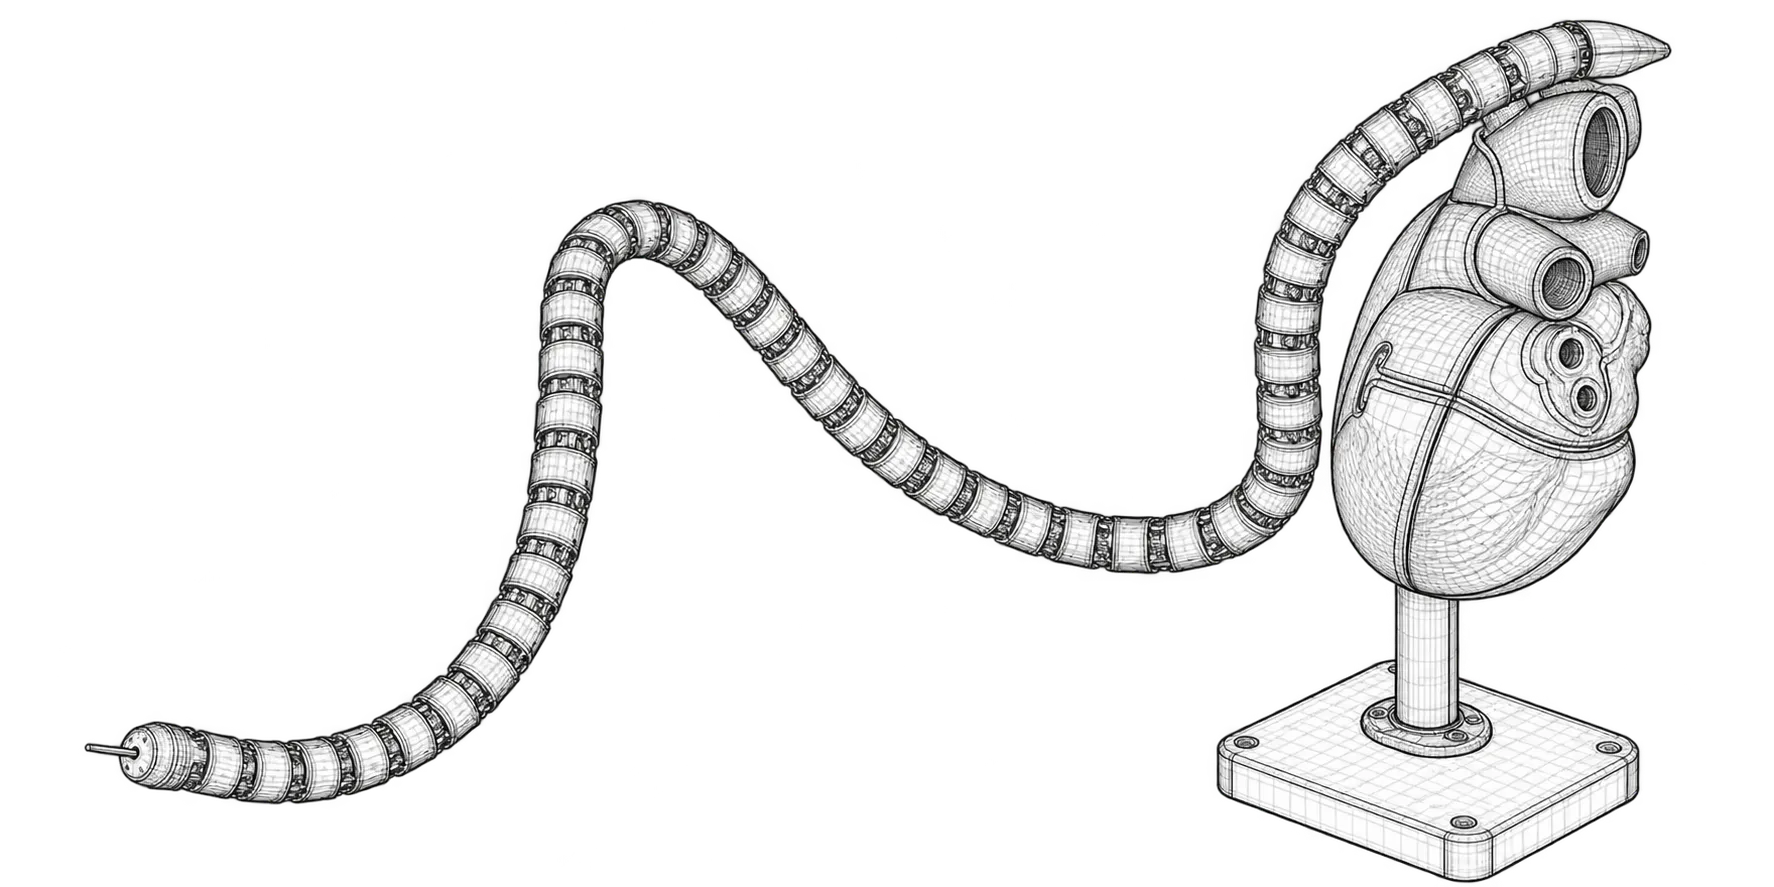
Contributed to the Highly Articulated Robotic Probe, a medical robot for minimally invasive cardiac surgery.
Engineering intern
Tormach
Prototyped and mechanically tested subsystems, identifying weaknesses and proposing design refinements.
Student researcher
Wyss Institute at Harvard University
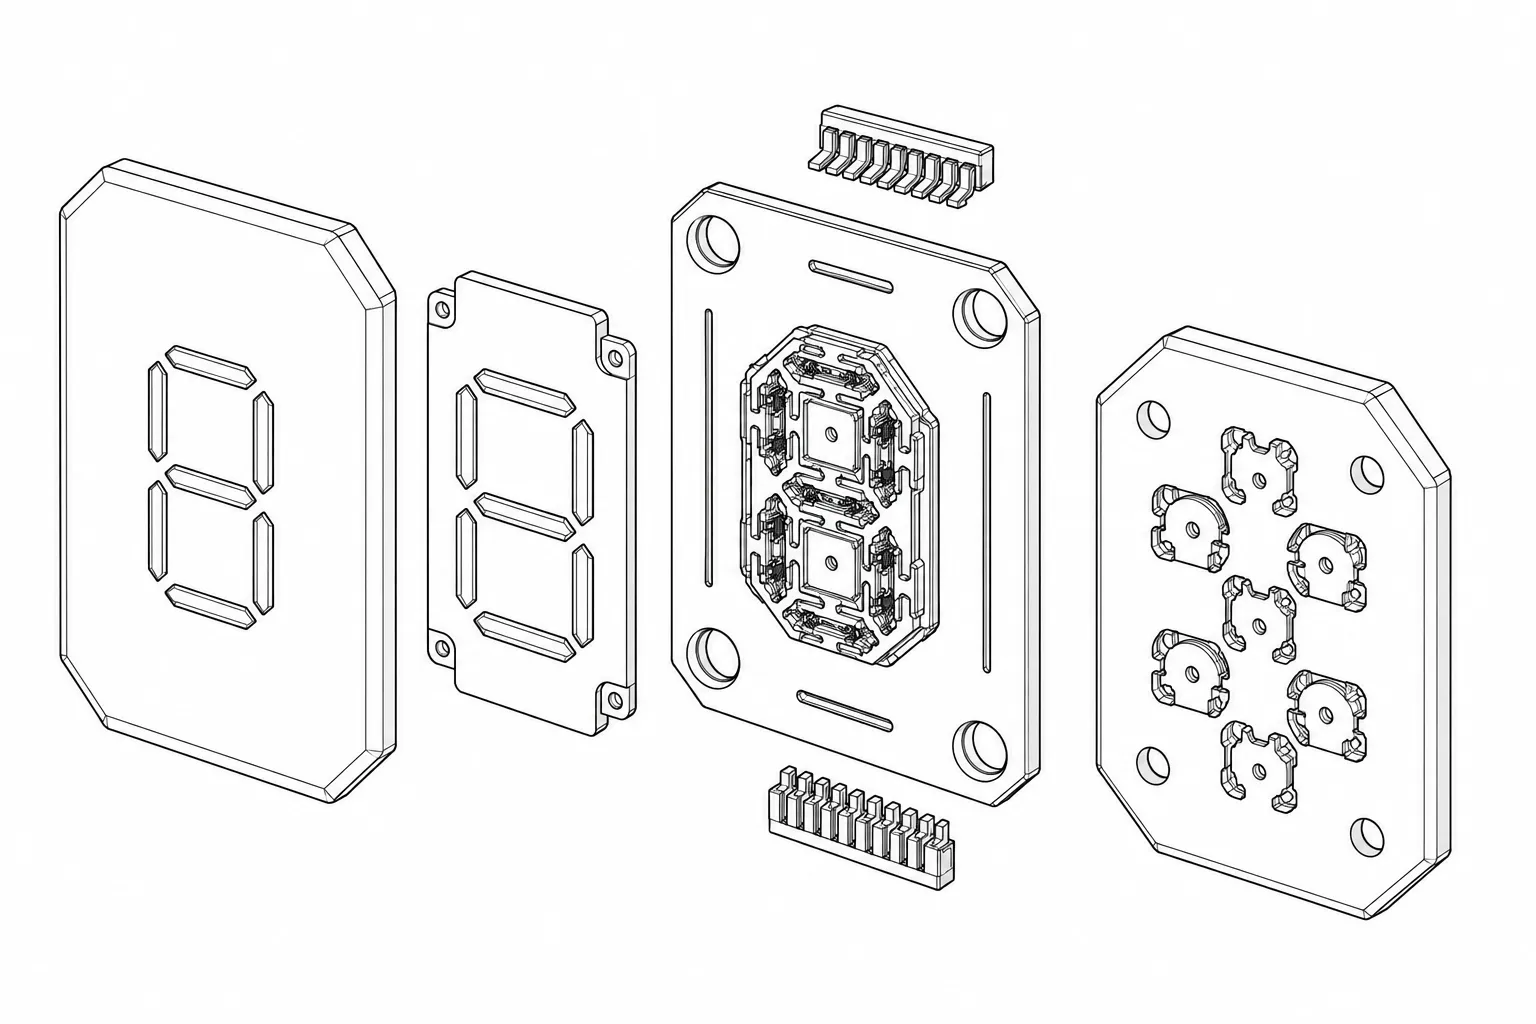
Researched and prototyped low-cost tactile display systems to improve accessibility for visually impaired users.